1
2
3
4
5
6
7
8
9
10
11
12
13
14
15
16
17
18
19
20
21
22
23
24
25
26
27
28
29
30
31
32
33
34
35
36
37
38
39
40
41
42
43
44
45
46
47
48
49
50
51
52
53
54
55
56
57
58
59
60
61
62
63
64
65
66
67
68
69
70
71
72
73
74
75
76
77
78
79
80
81
82
83
84
85
86
87
88
89
90
91
92
93
94
95
96
97
98
99
100
101
102
103
104
105
106
107
108
109
110
111
112
113
114
115
116
117
118
119
120
121
122
123
124
125
126
127
128
129
130
131
132
133
134
135
136
137
138
139
140
141
142
143
144
145
146
147
148
149
150
151
152
153
154
155
156
157
158
159
160
161
162
163
164
165
166
167
168
169
170
171
172
173
174
175
176
177
178
179
180
181
182
183
184
185
186
187
188
189
190
191
192
193
194
195
196
197
198
199
200
201
202
203
204
205
206
207
208
209
210
211
212
213
214
215
216
217
218
219
220
221
222
223
224
225
226
227
228
229
230
231
232
233
234
235
236
237
238
239
240
241
242
243
244
245
246
247
248
249
250
251
252
253
254
255
256
257
258
259
260
261
262
263
264
265
266
267
268
269
270
271
272
273
274
275
276
277
278
279
280
281
282
283
284
285
286
287
288
289
290
291
292
293
294
295
296
297
298
299
300
301
302
303
304
305
306
307
308
309
310
311
312
313
314
315
316
317
318
319
320
321
322
323
324
325
326
327
328
329
330
331
332
333
334
335
336
337
338
339
340
341
342
343
344
345
346
347
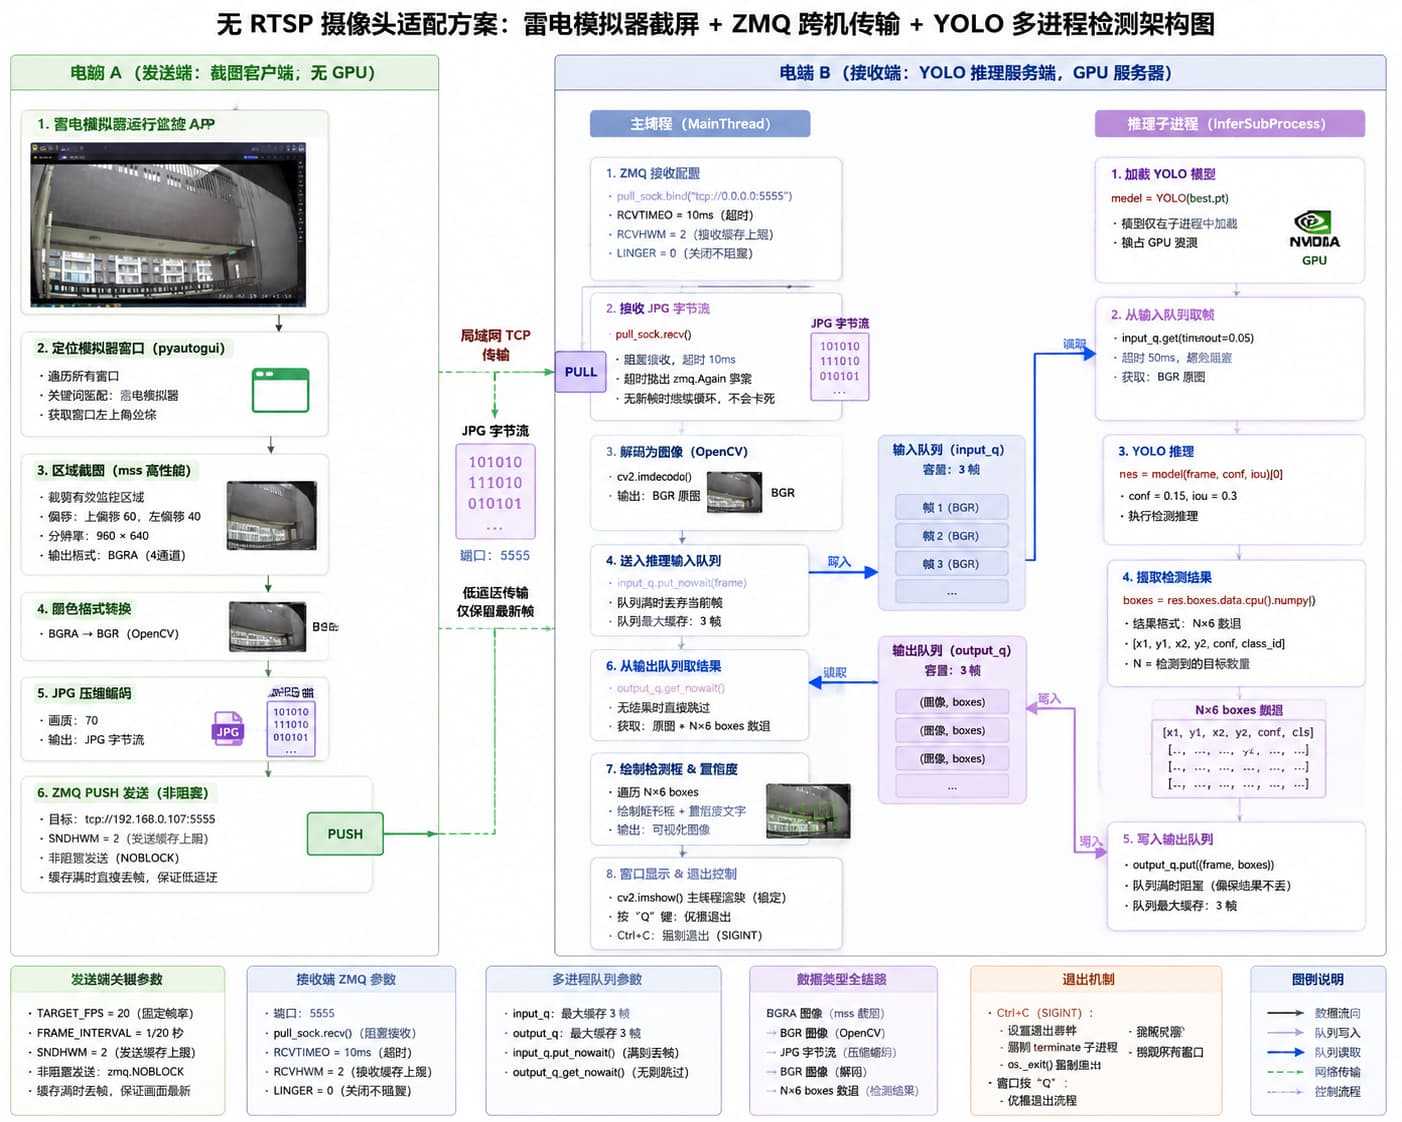
| import zmq
import cv2
import numpy as np
import signal
import os
import time
from datetime import datetime
from ultralytics import YOLO
from multiprocessing import Process, Queue, Event
from queue import Empty, Full
LISTEN_PORT = 5555
MODEL_PATH = r"runs/detect/train-8/weights/best.pt"
CONF_THRESH = 0.6
IOU_THRESH = 0.5
INFER_QUEUE_MAX = 6
ZMQ_RECV_HWM = 6
ZMQ_RECV_TIMEOUT = 5
WIN_NAME = "YOLO Pedestrian Detection"
YOLO_VERBOSE_PRINT = False
SAVE_VIDEO = True
VIDEO_QUEUE_MAX = 12
VIDEO_FPS = 15
VIDEO_DIR = "./runs/detect/ped_event_video"
VIDEO_EXT = ".mp4"
FOURCC = cv2.VideoWriter_fourcc(*"mp4v")
EVENT_GAP_SEC = 1.5
SHOW_FPS = 30
SHOW_INTERVAL_MS = int(1000 / SHOW_FPS)
WAIT_PROC_TIMEOUT = 3.5
SHOW_ORIGIN_FRAME = False
def infer_process(in_q: Queue, out_q: Queue, exit_evt: Event):
import signal
signal.signal(signal.SIGINT, signal.SIG_IGN)
try:
model = YOLO(MODEL_PATH)
print("[推理进程] YOLO模型加载完成", flush=True)
except Exception as e:
import traceback
print("[推理进程] 模型加载失败!", flush=True)
print(traceback.format_exc(), flush=True)
return
try:
while not exit_evt.is_set():
try:
frame = in_q.get(timeout=0.05)
except Empty:
continue
try:
res = model(frame, conf=CONF_THRESH, iou=IOU_THRESH, verbose=YOLO_VERBOSE_PRINT)[0]
boxes = res.boxes.data.cpu().numpy() if res.boxes else np.empty((0,6))
try:
out_q.put((frame, boxes), timeout=0.05)
except Full:
pass
except Exception as e:
import traceback
print("[推理进程] YOLO推理发生致命错误:", flush=True)
print(traceback.format_exc(), flush=True)
raise e
except KeyboardInterrupt:
pass
while True:
try:
out_q.get_nowait()
except Empty:
break
import torch
del model
if torch.cuda.is_available():
torch.cuda.empty_cache()
time.sleep(0.8)
print("[推理进程] 退出", flush=True)
def video_writer_process(vid_q: Queue, exit_evt: Event):
import signal
signal.signal(signal.SIGINT, signal.SIG_IGN)
os.makedirs(VIDEO_DIR, exist_ok=True)
writer = None
current_video_path = ""
frame_size = None
try:
while not exit_evt.is_set():
try:
msg = vid_q.get(timeout=0.1)
except Empty:
continue
msg_type = msg[0]
if msg_type == "start":
if writer is not None:
writer.release()
print(f"[录像进程] 上次事件文件已保存:{current_video_path}", flush=True)
draw_frame, start_ts = msg[1], msg[2]
h, w = draw_frame.shape[:2]
frame_size = (w, h)
file_name = f"ped_event_{start_ts}{VIDEO_EXT}"
current_video_path = os.path.join(VIDEO_DIR, file_name)
writer = cv2.VideoWriter(current_video_path, FOURCC, VIDEO_FPS, frame_size)
print(f"[录像进程] 新行人事件开始,创建视频:{current_video_path}", flush=True)
writer.write(draw_frame)
elif msg_type == "frame":
draw_frame = msg[1]
if writer is not None:
writer.write(draw_frame)
elif msg_type == "end":
if writer is not None:
writer.release()
print(f"[录像进程] 行人事件结束,文件保存完成:{current_video_path}", flush=True)
writer = None
current_video_path = ""
except KeyboardInterrupt:
pass
if writer is not None:
writer.release()
print(f"[录像进程] 程序退出,收尾视频:{current_video_path}", flush=True)
else:
print("[录像进程] 退出", flush=True)
def main():
exit_event = Event()
input_q = Queue(maxsize=INFER_QUEUE_MAX)
output_q = Queue(maxsize=INFER_QUEUE_MAX)
infer_proc = Process(target=infer_process, args=(input_q, output_q, exit_event), daemon=True)
infer_proc.start()
print(f"[主线] YOLO推理进程启动")
vid_queue = None
vid_proc = None
if SAVE_VIDEO:
vid_queue = Queue(maxsize=VIDEO_QUEUE_MAX)
vid_proc = Process(target=video_writer_process, args=(vid_queue, exit_event), daemon=True)
vid_proc.start()
print(f"[主线] 录像进程启动,每个行人事件将独立保存至 {VIDEO_DIR}")
def safe_put_end(q: Queue):
try:
q.put_nowait(("end",))
except Full:
try:
q.get_nowait()
q.put_nowait(("end",))
except Empty:
pass
def stop_recording(vid_proc):
if vid_proc and vid_proc.is_alive():
safe_put_end(vid_queue)
time.sleep(0.2)
is_recording = False
no_ped_start_time = None
def sigint_handler(sig, frame):
print("\n收到Ctrl+C,准备退出,等待资源收尾...", flush=True)
while True:
try:
input_q.get_nowait()
except Empty:
break
exit_event.set()
signal.signal(signal.SIGINT, sigint_handler)
ctx = zmq.Context()
pull_sock = ctx.socket(zmq.PULL)
pull_sock.setsockopt(zmq.RCVHWM, ZMQ_RECV_HWM)
pull_sock.setsockopt(zmq.RCVTIMEO, ZMQ_RECV_TIMEOUT)
pull_sock.setsockopt(zmq.LINGER, 0)
pull_sock.bind(f"tcp://0.0.0.0:{LISTEN_PORT}")
cv2.namedWindow(WIN_NAME, cv2.WINDOW_AUTOSIZE)
print(f"[主线] 检测服务启动,监听端口 {LISTEN_PORT} | Ctrl+C / Q键退出")
zero_frame = np.zeros((480,640,3), dtype=np.uint8)
last_draw = zero_frame
last_show_time = time.time()
try:
while not exit_event.is_set():
frame = None
try:
jpg_bytes = pull_sock.recv()
arr = np.frombuffer(jpg_bytes, np.uint8)
frame = cv2.imdecode(arr, cv2.IMREAD_COLOR)
except zmq.Again:
pass
if frame is not None:
try:
input_q.put_nowait(frame)
except Full:
pass
draw = None
has_ped = False
try:
img, boxes = output_q.get_nowait()
draw = img.copy()
has_ped = len(boxes) > 0
for b in boxes:
x1, y1, x2, y2 = map(int, b[:4])
conf, cls = b[4:]
cv2.rectangle(draw, (x1,y1), (x2,y2), (0,255,0), 2)
cv2.putText(draw, f"{conf:.2f}", (x1,y1-6), cv2.FONT_HERSHEY_SIMPLEX,0.45,(0,255,0),1)
last_draw = draw
except Empty:
pass
draw = draw if draw is not None else last_draw
show_current_frame = False
now = time.time()
if SHOW_ORIGIN_FRAME:
if frame is not None:
cv2.imshow(WIN_NAME, frame)
if (now - last_show_time) * 1000 >= SHOW_INTERVAL_MS:
if not SHOW_ORIGIN_FRAME:
cv2.imshow(WIN_NAME, draw)
last_show_time = now
show_current_frame = True
key = cv2.waitKey(5)
if key & 0xFF == ord("q"):
while True:
try:
input_q.get_nowait()
except Empty:
break
break
if not SAVE_VIDEO:
continue
if SHOW_ORIGIN_FRAME:
continue
if not show_current_frame:
continue
now_ts = datetime.now().strftime("%Y%m%d_%H%M%S")
now_sec = time.time()
if has_ped:
no_ped_start_time = None
if not is_recording:
try:
vid_queue.put_nowait(("start", draw, now_ts))
except Full:
pass
is_recording = True
else:
try:
vid_queue.put_nowait(("frame", draw))
except Full:
pass
else:
if is_recording:
if no_ped_start_time is None:
no_ped_start_time = now_sec
gap_duration = now_sec - no_ped_start_time
if (gap_duration < EVENT_GAP_SEC):
try:
vid_queue.put_nowait(("frame", draw))
except Full:
pass
else:
safe_put_end(vid_queue)
is_recording = False
no_ped_start_time = None
finally:
stop_recording(vid_proc)
exit_event.set()
time.sleep(1.5)
print("[主线] 等待推理进程退出...", flush=True)
if infer_proc.is_alive():
infer_proc.join(timeout=WAIT_PROC_TIMEOUT)
if infer_proc.is_alive():
print("[警告] 推理进程超时未退出,强制终止", flush=True)
infer_proc.terminate()
infer_proc.join()
if vid_proc is not None and vid_proc.is_alive():
print("[主线] 等待录像进程退出...", flush=True)
vid_proc.join(timeout=WAIT_PROC_TIMEOUT)
if vid_proc.is_alive():
print("[警告] 录像进程超时未退出,强制终止", flush=True)
vid_proc.terminate()
vid_proc.join()
pull_sock.close()
ctx.term()
cv2.destroyAllWindows()
print("[主线] 程序资源全部释放完毕")
if __name__ == "__main__":
main()
|